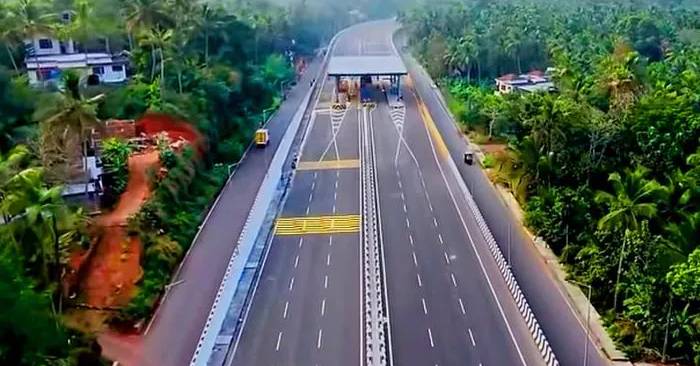
Kannur: National Highway-66 in Kerala is set to implement a cutting-edge toll collection system using GPS and AI camera technology. This innovative approach charges tolls based on the distance traveled, eliminating revenue loss even if entry and exit points increase. The new system also ensures that toll evasion becomes nearly impossible, while allowing vehicles to continue their journey without stopping for toll payments.
The toll collection process relies on onboard units or tracking devices installed in vehicles, using the Global Navigation Satellite System (GNSS). GPS trackers will monitor vehicle locations, calculate the kilometers traveled via satellite, and automatically deduct the corresponding toll amount from the user’s account. To enhance accuracy, the GAGAN system (GPS Aided Geo Augmented Navigation) will be integrated into the setup. Vehicle owners will need to install the onboard units, and discussions are underway to include these systems in newly manufactured vehicles.
Additionally, trial runs of Automatic Number Plate Recognition (ANPR) cameras have started on select national highways. KELTRON, which has successfully deployed AI-powered cameras across Kerala’s roads, is exploring the inclusion of this technology for toll collection. These cameras can precisely capture and analyze vehicle number plates to calculate tolls based on location and travel details.
NH-66, spanning from Kasaragod to Thiruvananthapuram, features entry and exit points every one to five kilometers. The connection between the national highway and service roads within the same distance ensures easy access and exit on both sides of the road. This system promises to transform toll collection, improving convenience for road users and streamlining operations for authorities.